Henry Noyes
I am a recent graduate of Northeastern University, where I received a Master of Science in Robotics. My research focused on developing autonomous control for a multi-modal snake robot. I was advised by Professor Alireza Ramezani in the Silicon Synapse Lab.
My studies were supported by a NASA Space Technology Graduate Research Fellowship. I have researched contact-aware reinforcement learning for snake robot locomotion, demonstrated whole-body loco-manipulation using a snake robot, and built computer vision frameworks for a DARPA-funded mixed reality project.
I am passionate about space exploration and the science of machine intelligence. In my free time, I like to build things.
News
-
8/13/26Our work on contact-aware reinforcement learning is accepted to IROS 2026 Workshop on Contact & Learning.
-
8/12/26I successfully defended my master's thesis, Toward Autonomy on a Multi-modal Snake Robot.
-
6/16/26Our work on whole-body loco-manipulation is accepted to IROS 2026!
-
6/1/26I have joined NASA JPL for the summer to work on reinforcement learning for snake robot control.
Papers
 |
Northeastern University, 2026
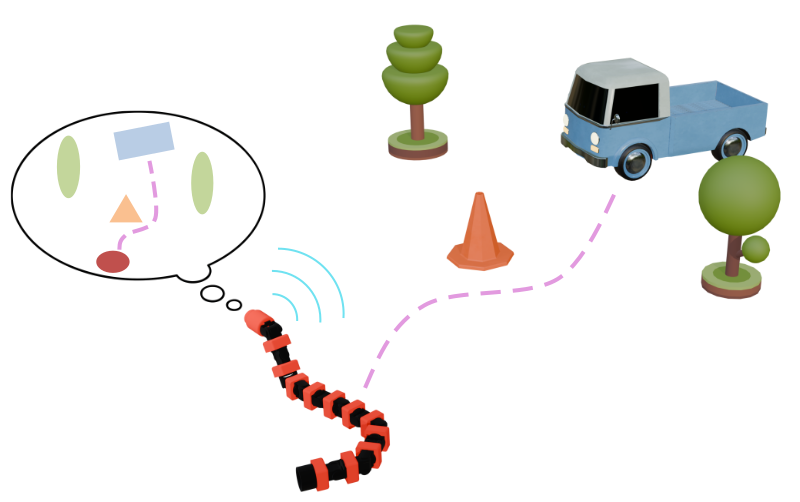
Snake robots are highly adaptable robotic platforms capable of operating in diverse and unstructured domains. However, their contact-rich locomotion and redundant morphology present challenges for robust control, limiting the autonomy level of existing platforms. This thesis addresses this gap by developing an autonomous architecture for COBRA (Crater Observing Bio-inspired Rolling Articulator), a multi-modal snake robot designed to explore lunar craters.
|
 |
Workshop on Contact & Learning, IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
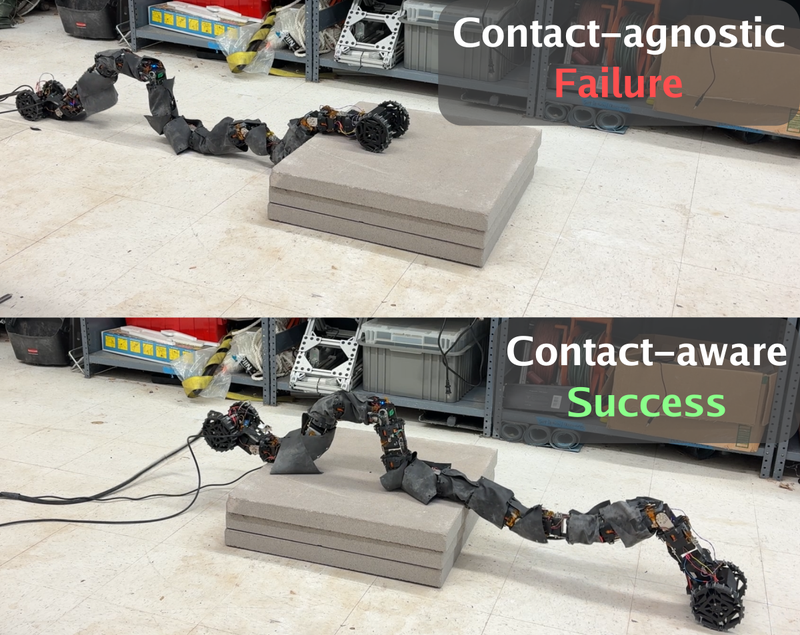
We present contact-aware reinforcement learning onboard the Garden EELS robot. Custom force-sensing modules are implemented to provide exteroceptive measurements of contact interactions. On hardware, the contact-aware policy demonstrates a higher success rate in a step climbing task when compared to the policy without contact feedback.
|
 |
IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
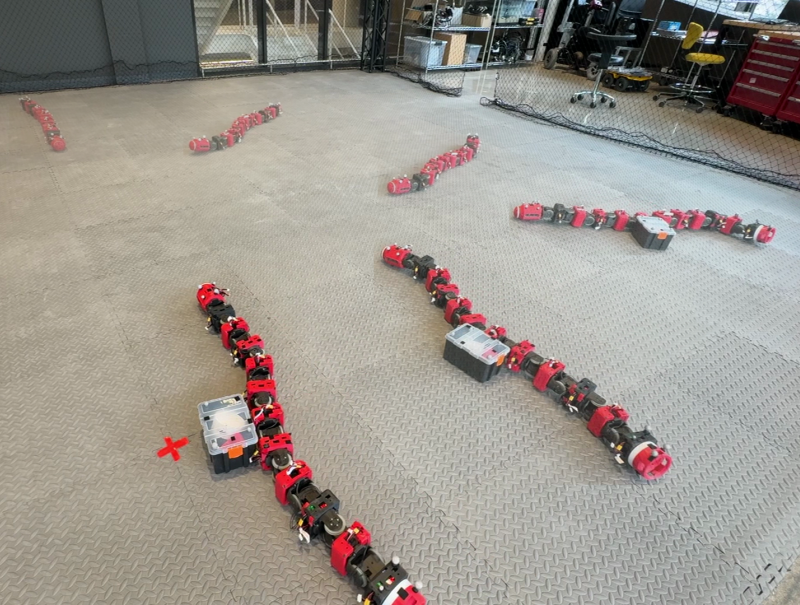
We present closed-loop, whole-body loco-manipulation with our snake robot COBRA. We validate the planner and controller on hardware to autonomously push an object to a goal location during sidewinding.
|
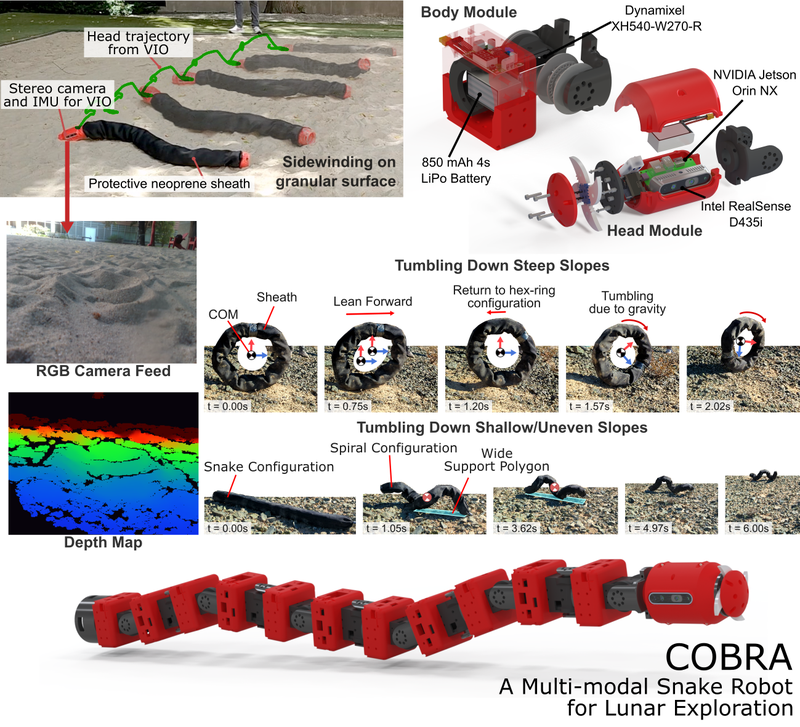 |
Advanced Intelligent Systems, September 2025
Crater Observing Bio-inspired Rolling Articulator (COBRA) is a modular, snake-inspired robot that addresses the mobility challenges of extraterrestrial exploration sites such as Shackleton Crater. We present the robot's design, dynamic modeling, high-fidelity simulations, and field validation demonstrating its multi-modal capabilities.
|
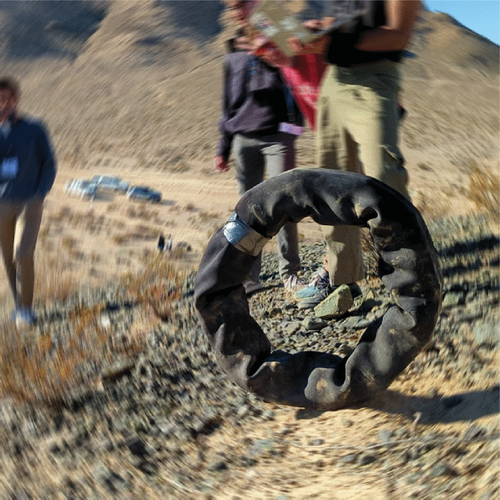 |
IEEE/ASME International Conference on Advanced Intelligent Mechatronics, 2024
In the 2022 NASA BIG Idea Challenge, Northeastern University won NASA's top Artemis Award award by proposing an articulated robot tumbler called COBRA (Crater Observing Bio-inspired Rolling Articulator). This report briefly explains the underlying principles that made COBRA successful in competing with other concepts ranging from cable-driven to multi-legged designs from six other participating US institutions.
|
Work
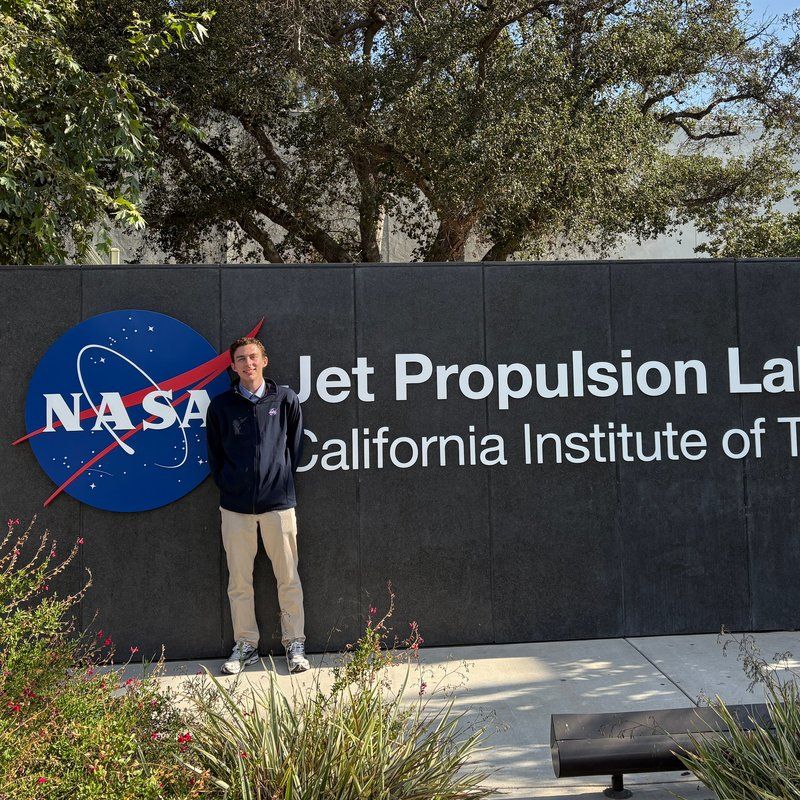 |
Visiting Graduate Researcher, Robotic Surface Mobility Group, NASA Jet Propulsion Laboratory
Pasadena, CA
As part of my NSTGRO Fellowship, I spent a summer at NASA JPL exploring reinforcement learning for snake robot locomotion. I investigated the influence of contact observations in a step climbing task, successfully deploying trained policies onboard a force-sensing snake robot. |
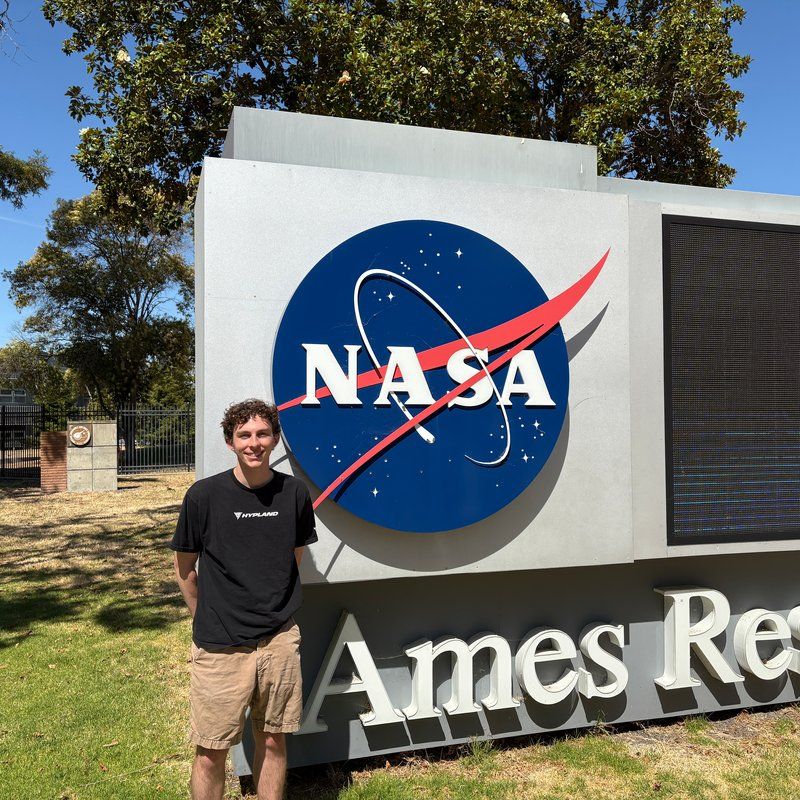 |
Visiting Graduate Researcher, Intelligent Robotics Group, NASA Ames Research Center
Mountain View, CA
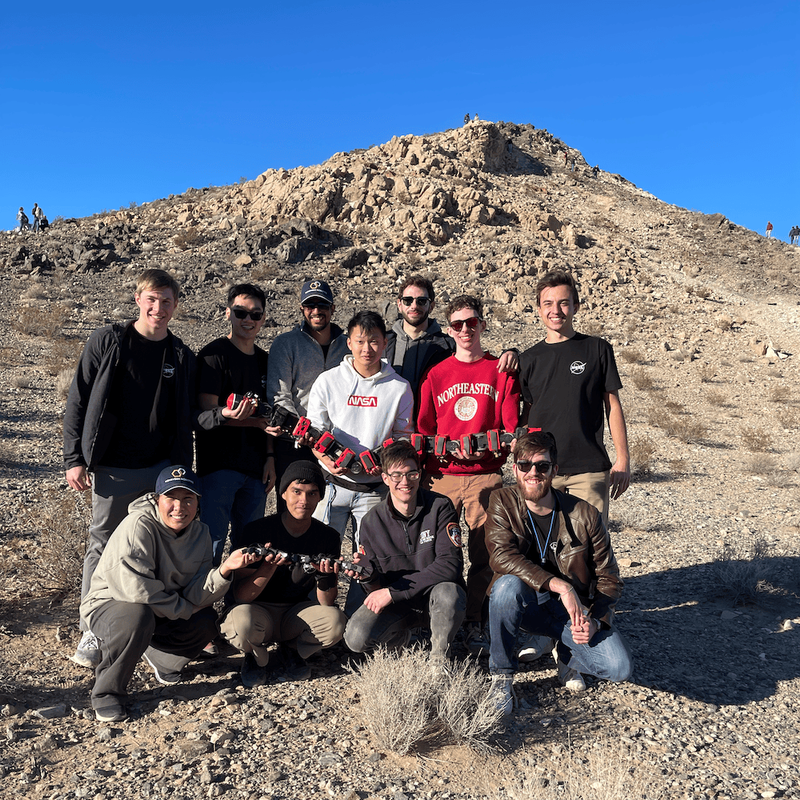
As part of my NSTGRO Fellowship, I spent a summer at NASA ARC researching novel mobility solutions for crater exploration. I developed a method for tumbling tensegrity robot control, validating the framework in simulation and real-world experiments. |
 |
Student Researcher, Silicon Synapse Lab, Northeastern University
Boston, MA
I spent over four years as a researcher in the Silicon Synapse Lab under Professor Alireza Ramezani. As an undergraduate student, I was the electrical lead for COBRA (Crater Observing Bio-inspired Rolling Articulator), a modular snake-like robot that won 1st place in the 2022 NASA BIG Idea Challenge. COBRA has been featured by National Geographic, NASA, and WIRED, and has been published in top robotics conferences.
|
 |
Robotics Engineer, RIVeR Lab, Northeastern University
Boston, MA
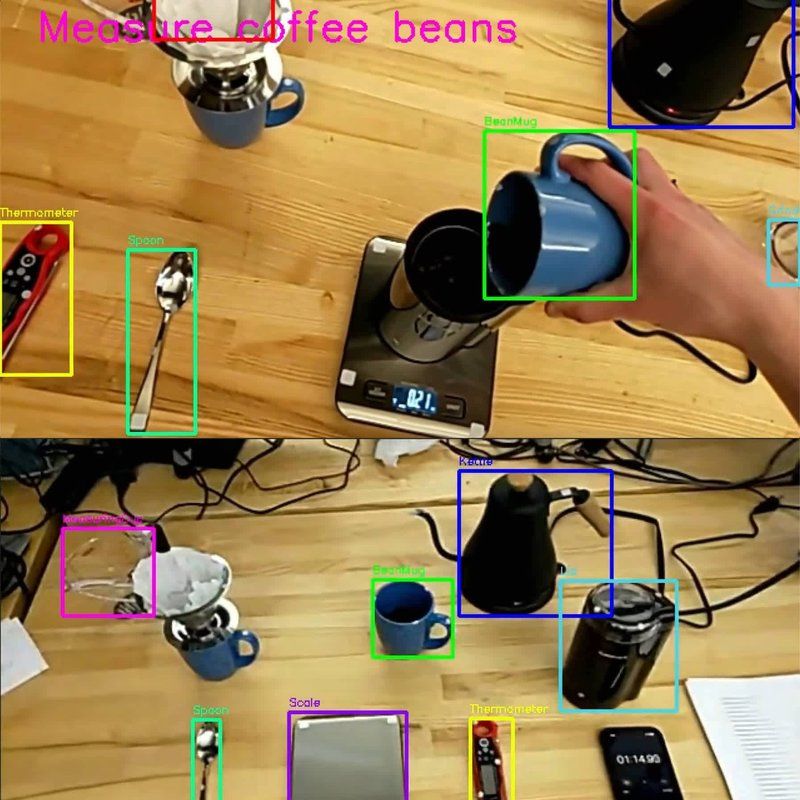
During my time in RIVeR, I led the data processing and system integration efforts on a DARPA-funded mixed reality project focused on perceptually-enabled task guidance (PTG). I developed a ROS2 architecture to efficiently collect and store data from the Microsoft HoloLens 2 headset. I also assisted in training object detection and action recognition models, and created an automated object annotation pipeline using OptiTrack motion capture. |
 |
Plasma Engineer, MAAT Energy
Cambridge, MA
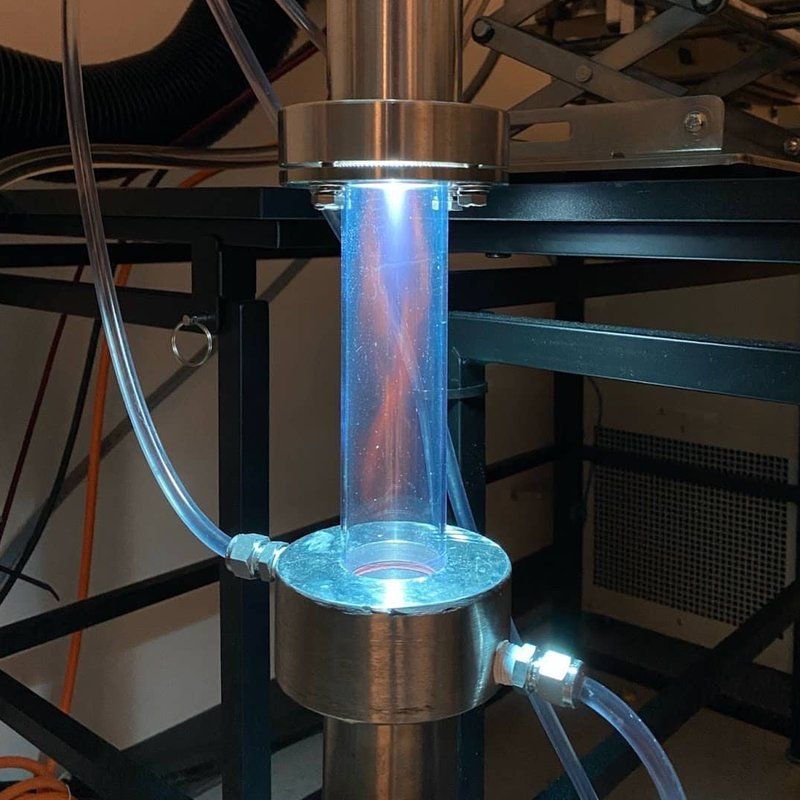
In my six-month co-op at MAAT, I modeled electromagnetic fields in COMSOL to assist plasma applicator design. I also developed, fabricated, and tested 3 novel solutions to microwave plasma ignition that are scalable to high-power systems. At the end of my co-op, I consolidated my work in several reports submitted to the U.S. Department of Energy. |